Material handling
How a part gets to the next operation.
We design how a part is gripped, moved, oriented, and handed off to the next step of the production process.
Material handling in the process
Moving the part is part of the operation itself.
Sometimes a machine or station completes its part of the job, but the part still needs to be correctly picked up, oriented, and prepared for the next step.
Material handling determines how that handoff happens.
How the handoff happens
Where the part is picked up
How it is gripped
How it needs to be oriented
How it is handed off further
Result
moving the part has to be part of the operation itself, not an afterthought.
Typical tasks
Clear steps around a machine or workstation.
We define the solution based on the part's path directly at the operation, not the broader transport across production.
Picking up the part
Picking the part from a machine, station, or prepared location.
Placement
Handing the part off to a defined location for the next step.
Orientation and turning
Changing the part's position ahead of further processing.
Positioning
Preparing the part in a defined position for the station or process.
Feeding
Directed feeding of the part into the immediately following operation.
Local handoff
Transferring the part between two directly connected process steps.
Solution design
Grip and motion define the actual process.
Robotic material handling only makes sense once it is aligned with the part, the workstation, and the sequence of the operation.
01
Part
Geometry, material, and required orientation.
02
Grip
How the part is picked up and held during movement.
03
Motion
Path, turning, positioning, and handoff of the part.
04
Machine or station
Where the part comes from and where it needs to go next.
05
Integration
Sequence, connected equipment, and vision where the task requires sensing, positioning, or inspection.
Related solutions
When material handling becomes part of a bigger problem.
CNC machine automation
When gripping and handing off the part is an inseparable part of tending a CNC machine.
See the solution→Injection molding automation
When removal, inserts, or part handling are part of the molding cycle.
See the solution→Collaborative robots
When a cobot is the right technology for the material-handling task.
See the solution→Internal logistics
When local handoff becomes a recurring flow between stations, containers, or production stages.
See the solution→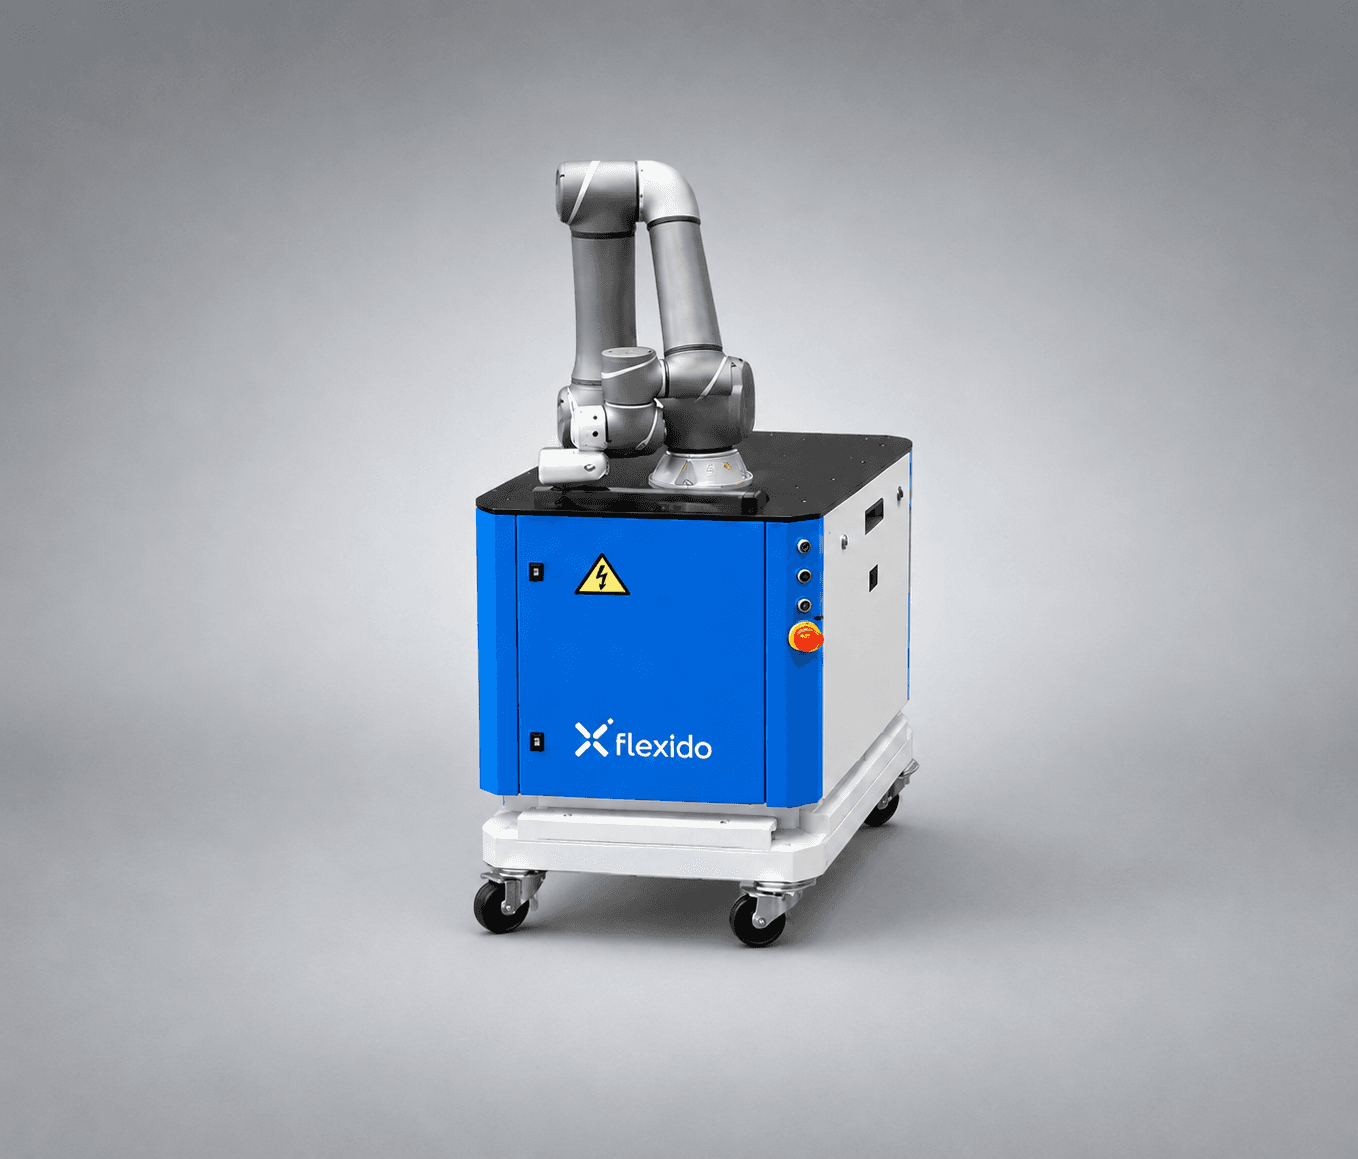
Related systems
TMX performs material-handling tasks in practice.
TMX is a mobile collaborative robot platform for pick and place, quality control, and simple assembly tasks — a concrete implementation of the material-handling tasks described above.
Contact
How does the part need to get to the next step?
Send us basic information about the part, its geometry, the current operation, the grip, the motion, the orientation, and the handoff to the machine or workstation.